Mujin Expands Standard Gripper Lineup: Next-Gen Intelligent Bag Grippers
Mujin introduces specialized intelligent robot grippers engineered specifically for heavy industrial bags: damage-free top-suction depalletizing and high-speed bottom-support stacking, powered by real-time digital twin simulations.
Automating the handling of heavy industrial bags—such as flour, grain, fertilizer, chemical pellets, and animal feed—has long been one of the toughest challenges in warehouse robotics. Unlike rigid corrugated cartons, bags deform continuously, shift their internal center of gravity in mid-air, and easily tear under localized mechanical stress.
To overcome these hurdles, Mujin has expanded its standard MujinGripper family with two new purpose-built robot hands designed specifically for heavy bag depalletizing and palletizing.
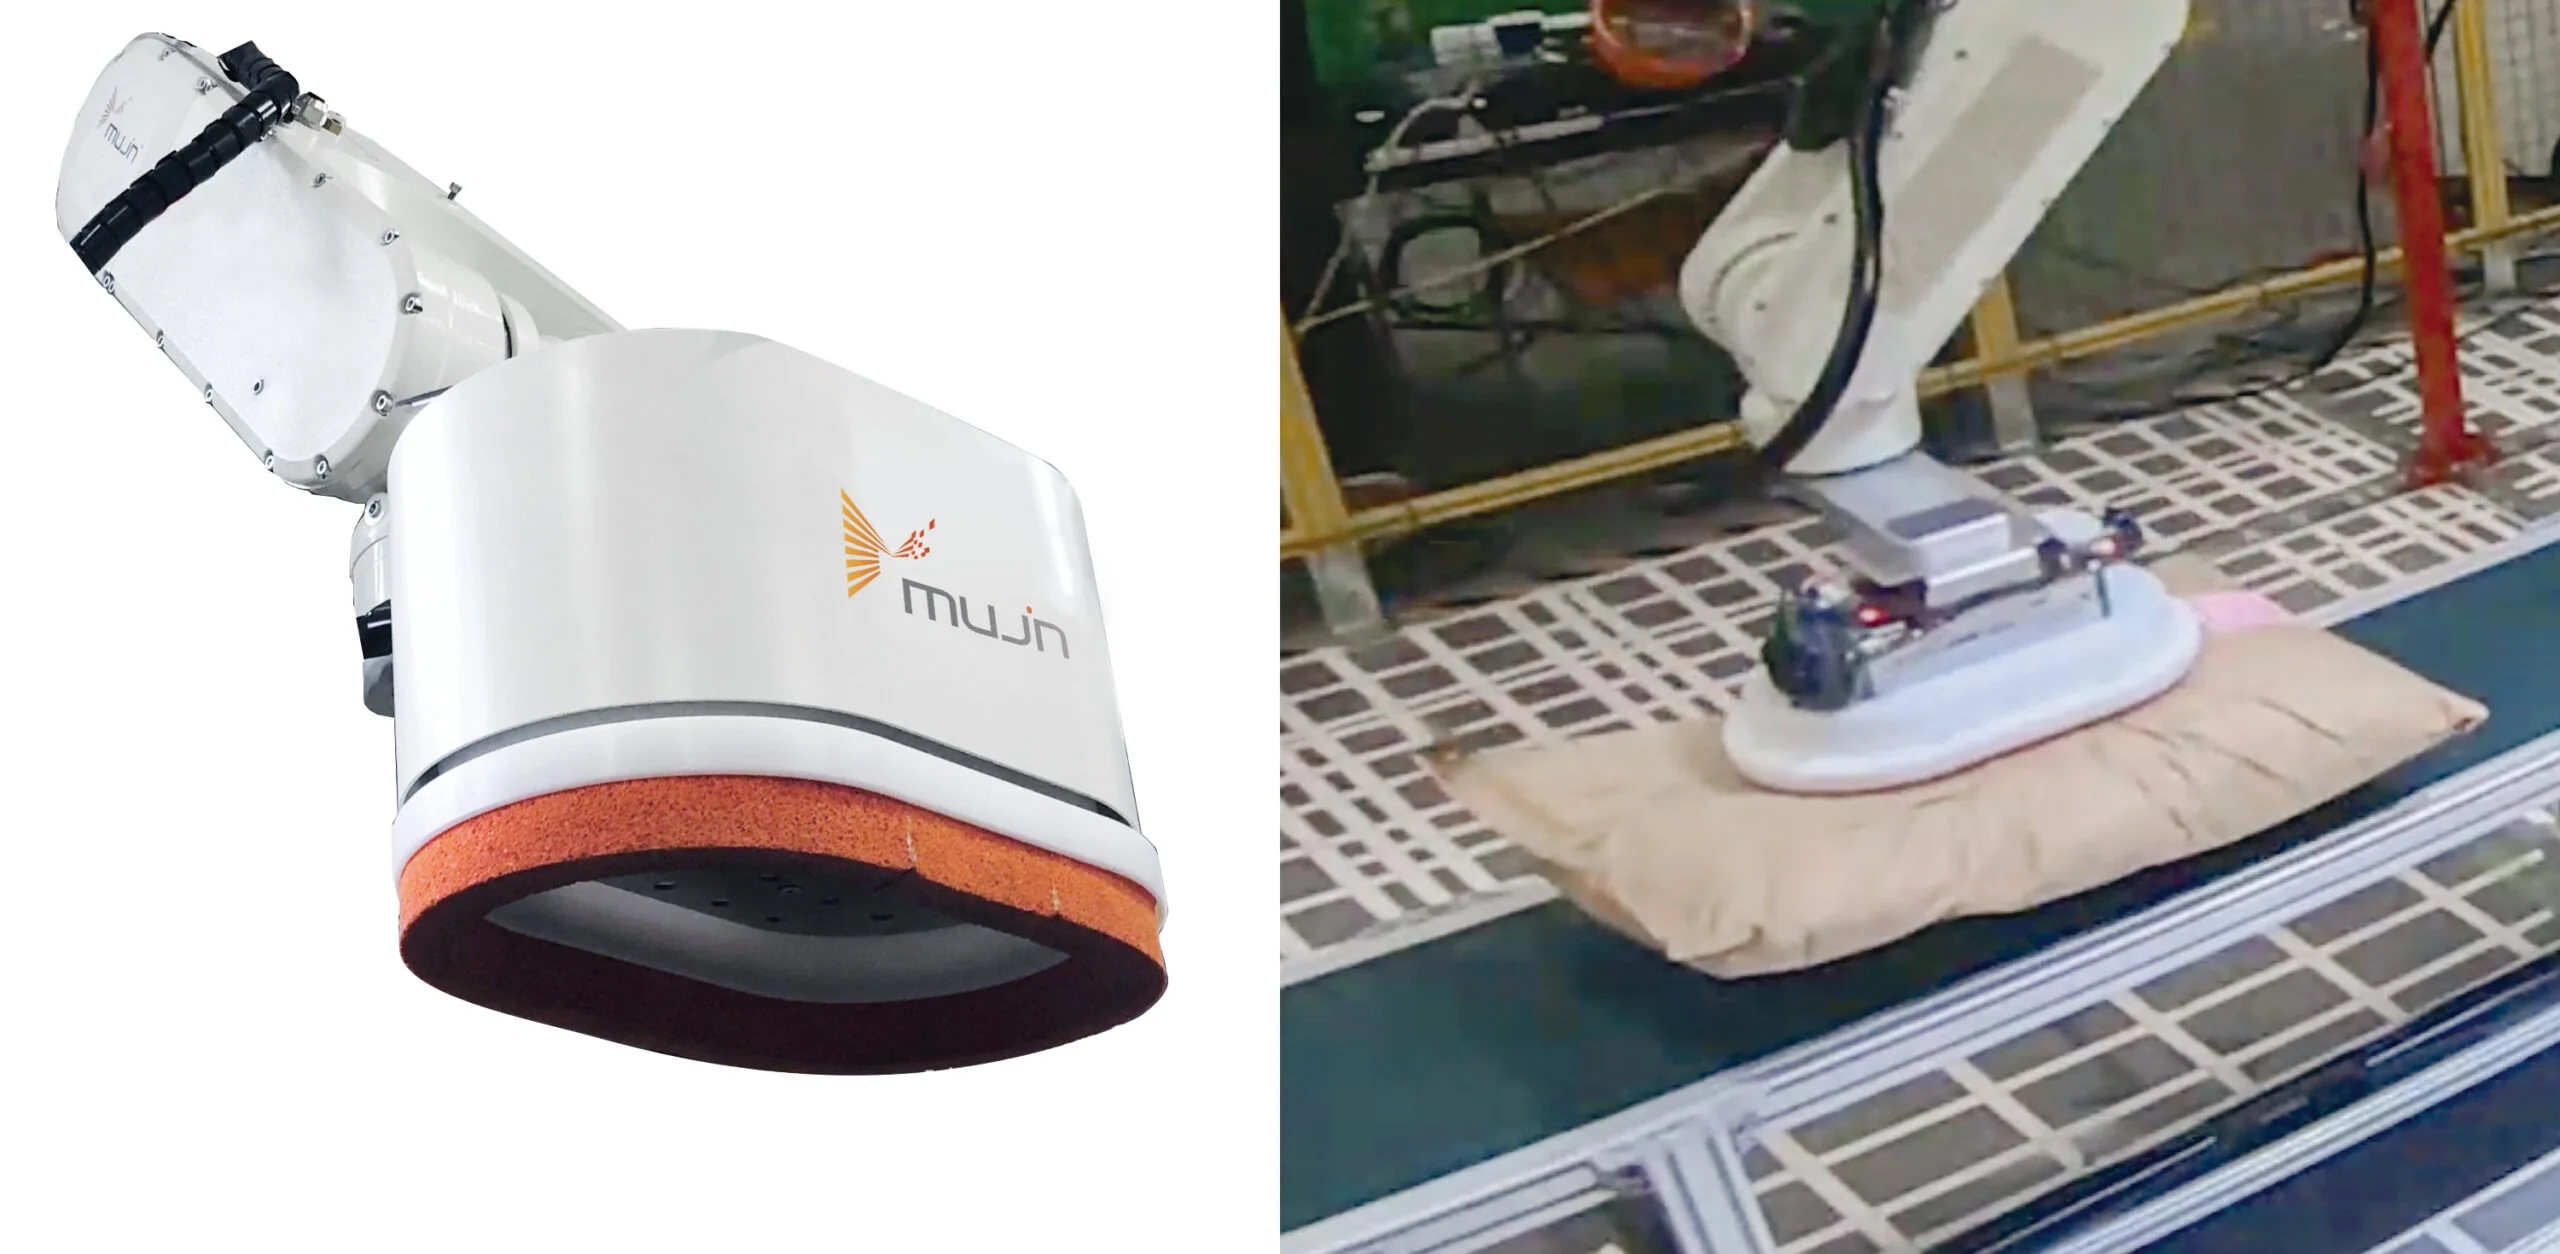
Mujin’s specialized bag robot hands: engineered for maximum stability, damage prevention, and high-throughput bag logistics
Two Specialized Grippers for Complete Bag Automation
To cover every phase of factory and warehouse bag logistics, Mujin developed two distinct gripper configurations tailored for loading/unloading versus precise pallet stacking:
1. Top-Suction Loading & Unloading Gripper
Zero-Damage High-Capacity Depalletizing
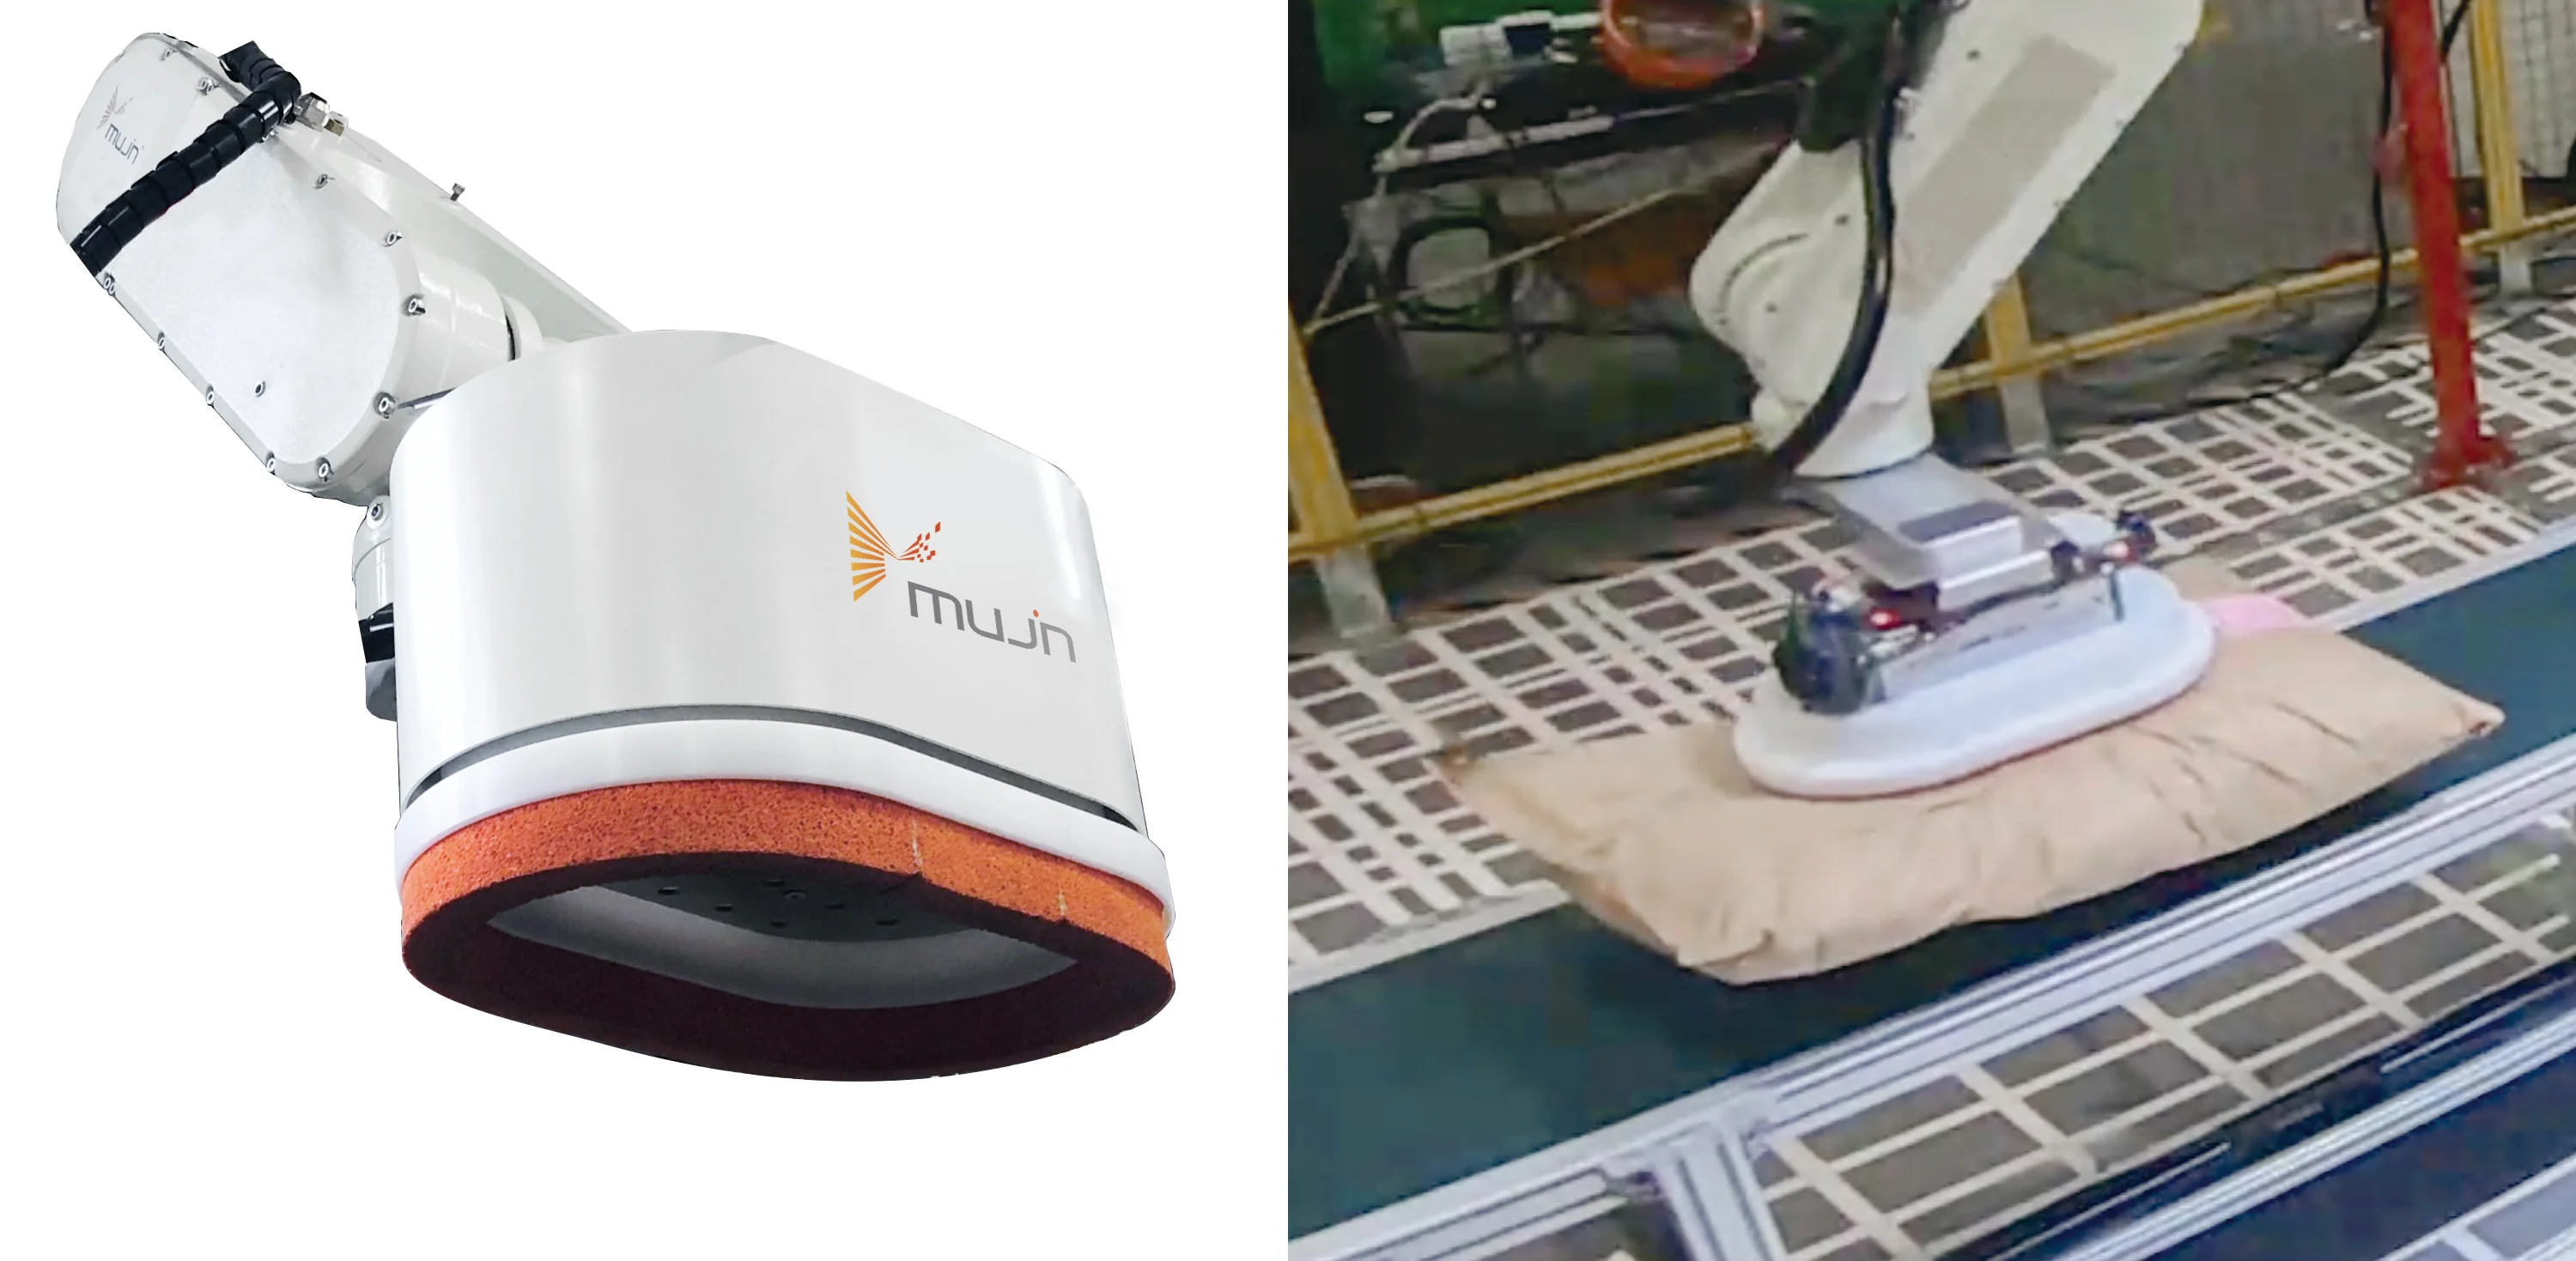
Designed to de-stack bags from pallets or conveyors without surface tearing. Multi-zone suction arrays adapt to variable porosity in multi-layer kraft paper, polypropylene, and woven fabrics up to 30 kg payload.
2. Bottom-Support High-Speed Stacking Gripper
Interlocked Palletizing Without Drop Risk
Combines gentle side clamping with bottom support fingers that cradle the bag during high-acceleration swings. Enables stable interlocking patterns and flush pallet placement at maximum speed.
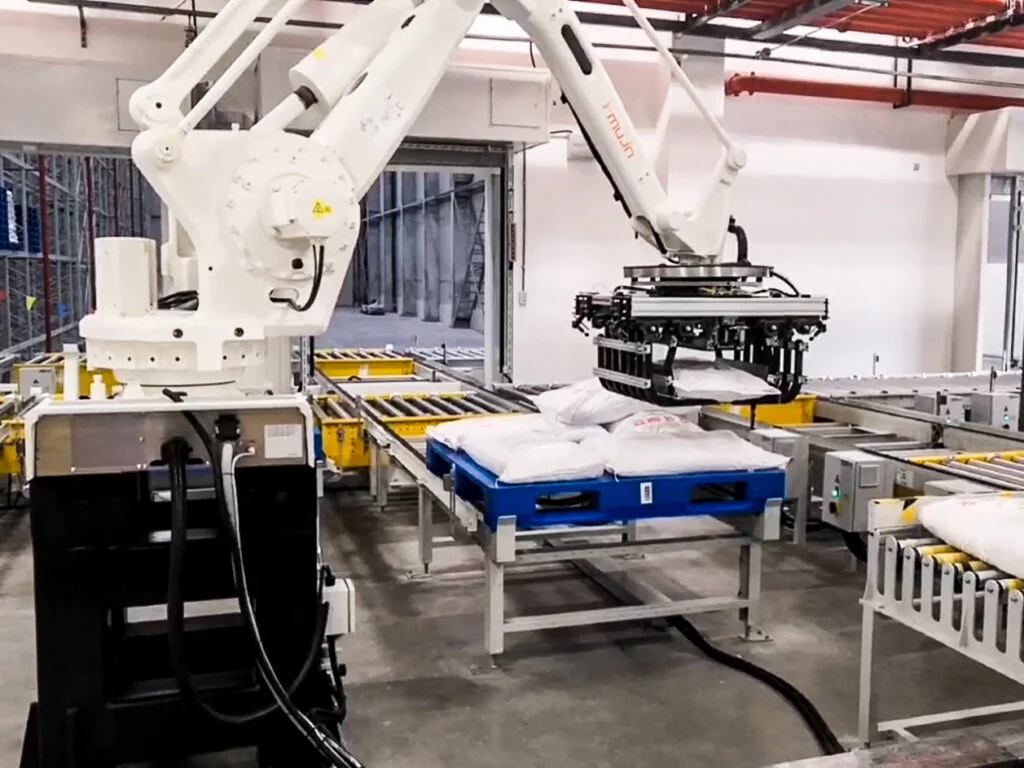
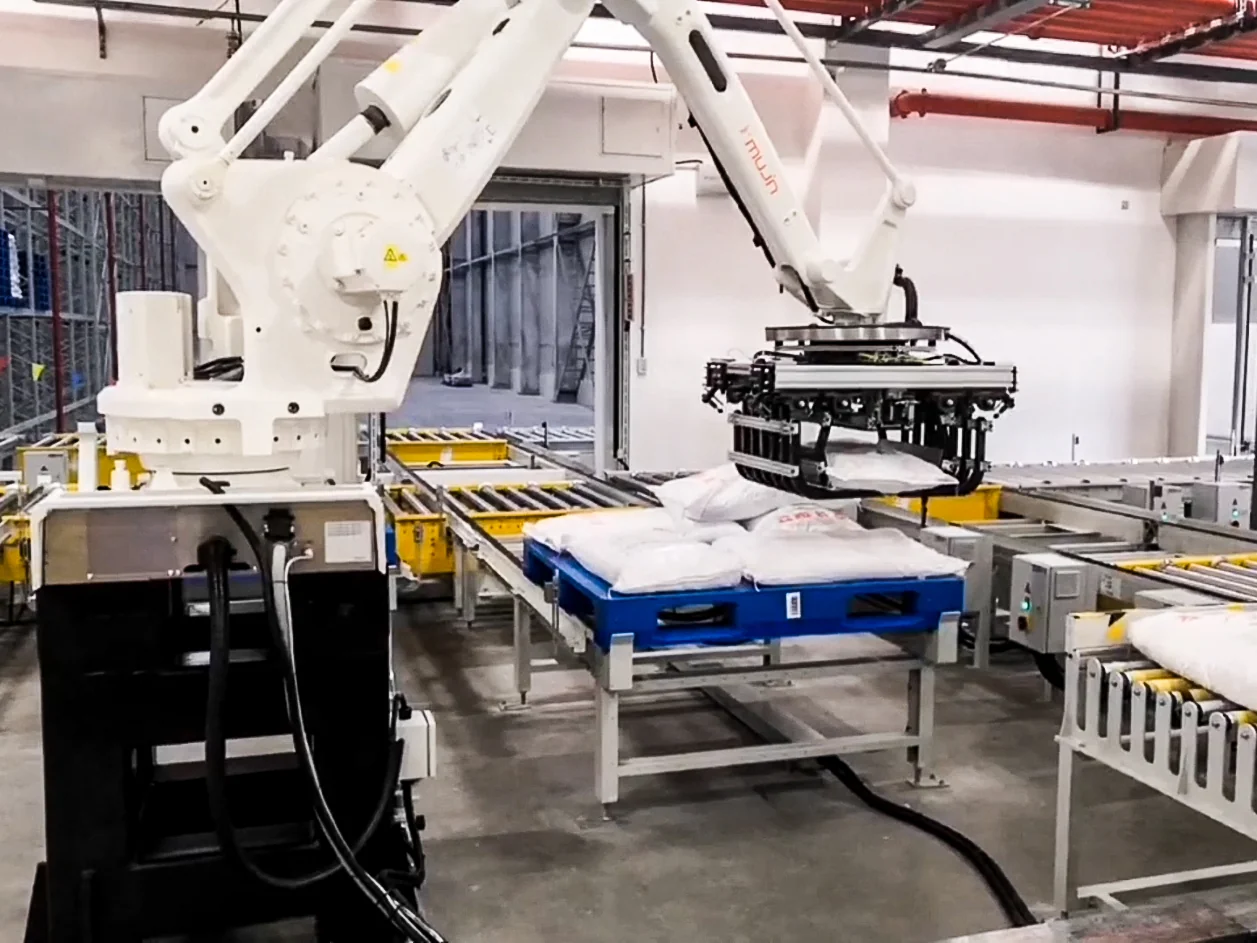
Bottom-support mechanical fingers securely holding and positioning heavy bags during rapid palletizing
Live operation: seamless bag pickup, real-time deformation compensation, and interlocking pallet placement
Software-First Engineering: Perfected via Digital Twin Simulations
In traditional factory automation, gripper designs are prototyped through costly trial-and-error, with real system capacity remaining an unknown risk until on-site commissioning.
At Mujin, hardware design is governed by advanced robot intelligence software. Before machining a single aluminum bracket or molding a suction cup, we simulate the complete physical system inside our real-time digital twin environment.
Simulating bag dynamics, center-of-gravity shifts, and robot trajectory clearance before physical fabrication
Pre-Validation of System Throughput
Simulate actual client bag samples, pallet patterns, and robot cycle times prior to deployment, guaranteeing throughput targets with zero operational surprises.
Dynamic 3D Vision Tracking
Proprietary Mujin 3D Vision algorithms scan bags in any orientation, identifying curvature, wrinkles, and tilt to guide the gripper to the ideal balance point.
Turnkey End-to-End Coordination with Peripheral Equipment
A truly efficient warehouse does not stop at the robot base. The new bag grippers operate under the unified orchestration of the MujinController, synchronizing robot arms with automated guided vehicles (AGVs/AMRs), conveyors, and pallet dispensers.
End-to-end integration: combining bag robotic cells, AGV transportation, and conveyor handoffs into a single turnkey solution
By combining deep software intelligence with modular, high-durability hardware, Mujin provides a complete answer to one of manufacturing’s most labor-intensive tasks—freeing workers from hazardous 30 kg heavy lifting while ensuring uninterrupted warehouse operations.