CURRENT SLIDE (STAGE)
NEXT SLIDE PREVIEW
SPEAKER NOTES
ノートはありません。
Don’t just move pixels on a screen.
Write code that moves the physical world.
Before diving into the global demographic shift: here is who we are, what we build, and our footprint at a glance.
Founded in 2011 by Dr. Rosen Diankov & Issei Takino. We don't manufacture robot arms; we build MujinOS—the software platform making any industrial machine intelligent and autonomous.
Ranked #1 in Japan startup funding with Series D completed. Backed by top institutional partners (NTT Group, QIA, SoftBank Vision Fund) fueling deep, long-term physical AI R&D.
Winner of the prestigious Prime Minister’s Award at the Japan Startup Awards 2026—officially recognized by the Japanese government as the nation's premier deep-tech robotics pioneer.
Headquartered in Tokyo with regional hubs in the US (Atlanta), Europe (Netherlands), and China (Guangzhou). An English-first engineering powerhouse representing 30+ nationalities.
Global supply chains and manufacturing face severe demographic decline and labor shortages. While LLMs automate digital workflows, the physical world still relies on exhausting manual labor and rigid, blind industrial machines.
Millions of workers trapped in repetitive, hazardous manual labor; traditional industrial robots remain blind, inflexible, and require weeks of manual point-by-point teaching for every layout change.
We turn industrial machines into autonomous, intelligent systems—solving the global supply chain crisis at its physical root.
We don't manufacture robot arms. We build the universal brain—the MujinController powered by MujinOS—that makes any hardware intelligent, vendor-agnostic, and autonomous out of the box.
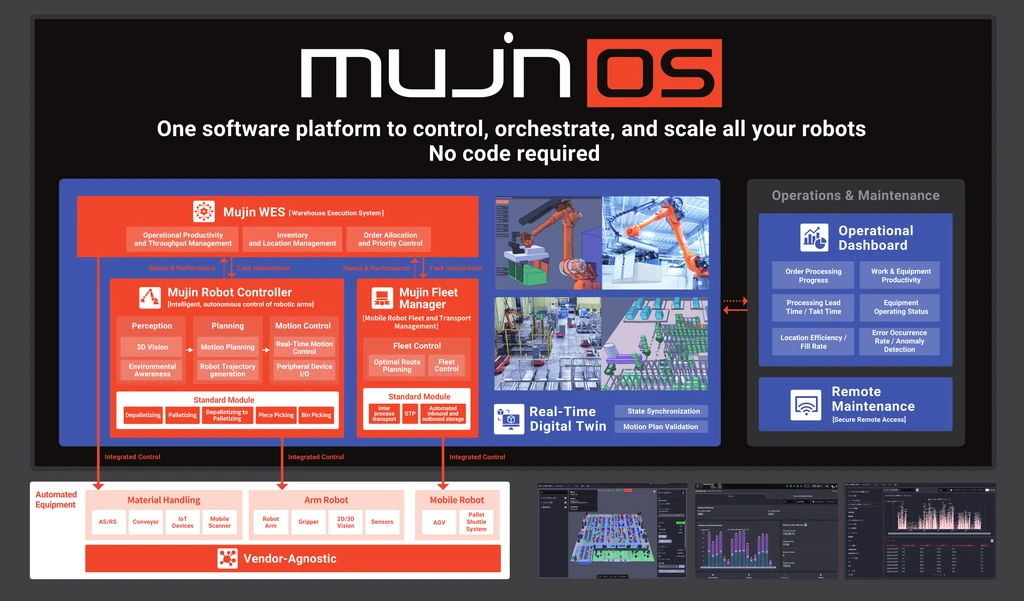
In an industrial facility where multi-ton robots move at high speeds, "99% accuracy" means catastrophic collisions every day. Purely probabilistic, black-box AI isn't enough. We pioneered MujinMI (Machine Intelligence).
End-to-end black-box policies suffer from opaque failure modes, require massive site-specific retraining, and offer zero mathematical safety guarantees when multi-ton arms move at full speed.
We combine targeted 3D ML perception with high-precision geometric modeling, dynamic motion planning, and real-time sensor fusion. 100% explainable, zero-teaching required, and guaranteed collision-free execution.
Four tightly coupled real-time subsystems executing deterministically on the edge—bridging 3D perception and physical actuation in milliseconds.
Computing optimal, collision-free trajectories in milliseconds across high degrees of freedom—without a single line of manual teaching.
High-speed 3D vision that handles chaotic lighting, reflective surfaces, and millions of unknown SKUs in real time.
Not just a 3D visualization. A real-time kinematic world model synchronized 1:1 with the physical cell, continuously fed by sensor fusion to enable dynamic trajectory planning.
Ultra-low-latency feedback loops connecting vision, planning, and actuator control to recover from real-world disturbances on the fly.
Why do top software engineers leave pure digital tech for Mujin? Because physical reality is the ultimate engineering constraint.
You cannot throw infinite cloud GPUs at the problem. Your C++ and Python code must compute complex graph searches and kinematics in milliseconds on the edge.
Gravity, friction, inertia, deformable packaging, and shifting center-of-mass. Your algorithms must conquer the messiness of the real world.
Synchronizing high-speed robot arms, conveyors, AS/RS cranes, and mobile robots (AGVs/AMRs) simultaneously without deadlocks or bottlenecks.
Moving from one-off bespoke engineering to the world’s first standardized, out-of-the-box physical AI robot products.
Our systems operate mission-critical production lines and logistics hubs for global industry leaders across retail, e-commerce, automotive, and manufacturing.
Handling mixed-SKU, custom-stacked, and unstable loads at superhuman speeds with zero master registration.
High-mix, vision-guided picking and dense tote packing for high-velocity e-commerce fulfillment centers.
Precision part feeding, machining tending, and internal factory logistics for automotive and industrial production lines.
Seamless real-time synchronization of AS/RS cranes, conveyors, robotic cells, and autonomous AGV/AMR fleets.
Backed by the Prime Minister’s Award and world-leading institutional partners to build the foundational OS for physical automation worldwide.
Ranked #1 in Japan startup funding (Series D completed, backed by NTT Group & QIA) fueling long-term R&D.
Headquartered in Tokyo, with expanding engineering and deployment operations across the US, Europe, and China.
A hyper-diverse community of robotics researchers, systems engineers, and deployment specialists.
Officially recognized by the Japanese government as the nation's premier startup at the Japan Startup Awards 2026, backed by an extensive global patent portfolio.
In Japanese manufacturing, Gemba (現場) means "the actual place where value is created."
Small, agile teams beat slow giants. We constantly innovate across every field with speed and efficiency.
We keep fighting until the last second until the robot moves reliably. A quitter never wins and a winner never quits.
Be the first to act and solve the root problem rather than wait. Don't find fault—find a remedy.
Always clarify the "why"—how your engineering creates real value for customers and aligns with team goals.
We don't build hobby toys; our products carry massive industrial responsibility. Persist in world-class quality.
Great things are built by teams. Respect differences across 30+ nationalities and inspire teammates to succeed.
Passion is the ultimate source of creativity and engineering power. The only way to do great work is to love what you do.
Where will your code live? Our R&D organization is structured around the core layers of the MujinOS and MujinController stack.
Motion planning, kinematics, dynamics, trajectory optimization, and multi-robot coordination (C++ / Python).
3D point cloud processing, deep learning pose estimation, synthetic data generation, and sensor calibration.
Distributed WES fleet control, Linux OS infrastructure, 3D WebGL UI, IoT portal, and developer tooling.
Ruggedized edge controller cabinets, embedded firmware, industrial IO/pendant systems, and 24/7 continuous operation testing.
Physical AI cannot be shipped like a SaaS app. Turning core technology into operational mega-warehouses requires world-class execution across every discipline.
Translating market bottlenecks into scalable MujinOS features, hardware certifications, and product roadmaps.
Designing robotic cells, commissioning systems on-site, and closing the real-world feedback loop with R&D.
Partnering with C-suite logistics and manufacturing leaders globally to architect warehouse transformation.
Controller manufacturing operations, supply chain, People Operations, and finance scaling our global footprint.
Simulators only take you 80% of the way. Solving the final 20%—where true breakthroughs happen—requires daily access to massive physical hardware and instant, face-to-face collaboration.
Our Tokyo HQ houses an expansive Robot Innovation Center packed with dozens of live industrial robots, AGVs, and 3D sensors from every major vendor. Write code at your desk, walk over to the floor, and deploy to multi-ton machines in minutes.
We are proudly an on-site, in-person organization. When a high-speed trajectory fails or a custom gripper slips, software, vision, hardware, and deployment engineers gather directly around the physical robot cell to diagnose edge cases on live hardware—eliminating weeks of remote back-and-forth.
Daily collaboration and documentation run in English. We provide end-to-end visa sponsorship, full relocation support to Tokyo, and community perks like free chef-prepared lunches.
We aren't looking for maintainers of a finished product. We are looking for pioneers to architect the next decade of physical automation.
Evolving from cell-level intelligence to autonomous, self-optimizing facility-wide operating systems.
Coordinating hundreds of heterogeneous robot arms, AS/RS cranes, and mobile robots in real-time synchronization with zero deadlocks.
Transforming industrial robotics from brittle, bespoke system integration into modular, repeatable products deployed at 10x velocity globally.
See the engineering for yourself. We’ve opened up our engineering architecture, team structures, and cultural principles for you to explore before you even apply.
Deep-dive into our MujinOS architecture, engineering blogs, Robot Innovation Center tour, and team interviews.
Find your place in Engineering, Product, Deployment, or Business across Tokyo, the US, Europe, and China.