---
title: "MujinMI Technology: The Machine Intelligence Making Industrial Robots Truly Autonomous"
description: "An engineering deep-dive into MujinMI (Machine Intelligence): high-speed analytical inverse kinematics, dynamic motion planning with real-world physics, situational 3D vision, and 1-in-40,000 industrial reliability."
type: blog
publishDate: "2024-02-28"
tags: ["Blog", "Mujin", "Technology", "Software"]
---
In the rapidly evolving landscape of industrial automation, Mujin stands at the technological frontier with **MujinMI (Machine Intelligence)**. While conventional factory robots blindly repeat rigid, manually taught trajectories, MujinMI transforms multi-axis manipulators into fully autonomous, production-ready systems that observe, reason, and adapt in real time.
---
### What is Machine Intelligence? (MI vs. AI)
The term "Artificial Intelligence" is frequently associated with neural networks and generative models that emulate human cognition. However, human decision-making is prone to cognitive biases, perceptual illusions, and statistical hallucinations. In safety-critical logistics hubs and high-speed manufacturing lines, **unpredictable behavior is completely unacceptable**—a single false move can crush goods, damage machinery, or cause safety shutdowns.
**MujinMI** takes an uncompromising approach: specialized intelligence engineered exclusively for machines. Rather than relying on stochastic black-box guesswork, MujinMI combines 100% rigorous mathematical calculations, real-time geometric reasoning, and physics-driven motion optimization.
**100% Deterministic**
Mathematically verifiable collision avoidance and kinematic feasibility computed in microseconds.
**Day-One Production**
No months of trial-and-error training or tedious manual teaching. Systems are production-ready on day one.
**Dynamic Adaptation**
Instantly handles workpiece variations, tilted pallets, and unexpected obstacles without human intervention.
:::note[Deterministic Safety vs. Black-Box Trial-and-Error]
Traditional reinforcement learning requires millions of simulated trials and still cannot mathematically guarantee zero collision. MujinMI provides closed-form mathematical guarantees on collision avoidance, joint velocity limits, and singularity prevention in every millisecond of motion.
:::
---
### Three Foundational Pillars of MujinMI
MujinMI achieves industrial autonomy through the tightly coupled execution of three proprietary software libraries:
#### 1. High-Speed Analytical Inverse Kinematics (IK)
Calculating how robot arm joints must position themselves to place a tool at a specific point in 3D space is the fundamental problem of Inverse Kinematics. Numerical solvers are slow and frequently get trapped in local minima or fail near singular configurations.
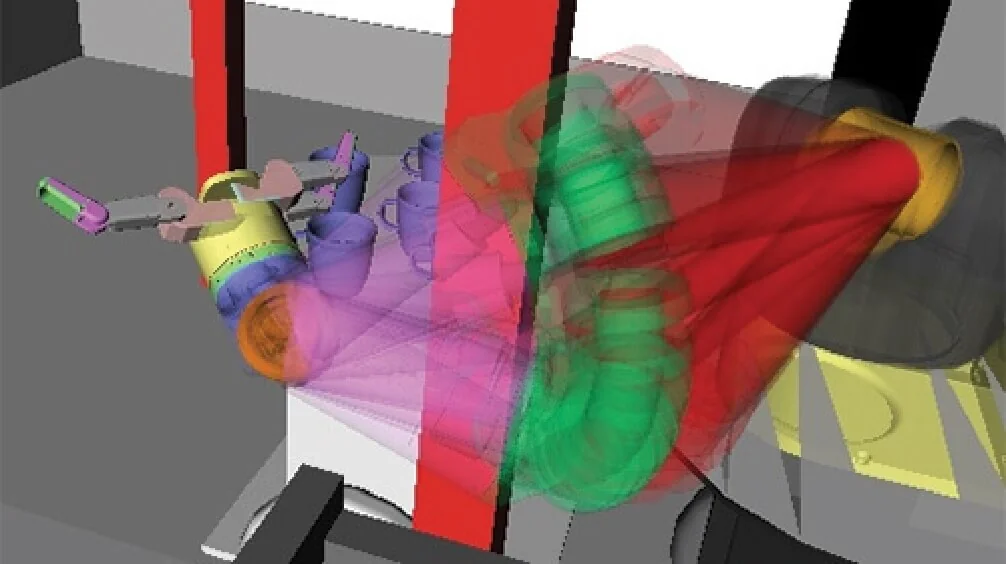
Mujin's analytical kinematics engine evaluates every mathematical branch in microseconds, selecting optimal joint solutions without singularity locks
Mujin has developed closed-form analytical kinematic solvers customized for diverse industrial manipulator geometries (from 6 degrees of freedom up to 10 degrees of freedom with external gantries and tracks). The algorithm solves equations in microseconds, effortlessly maneuvering around mathematical singularities and joint limits.
---
#### 2. Dynamic Motion Planning with Real-World Physics
In high-throughput distribution centers, robots must navigate cluttered, changing workspaces containing conveyors, safety fences, pallets, and adjacent arms.
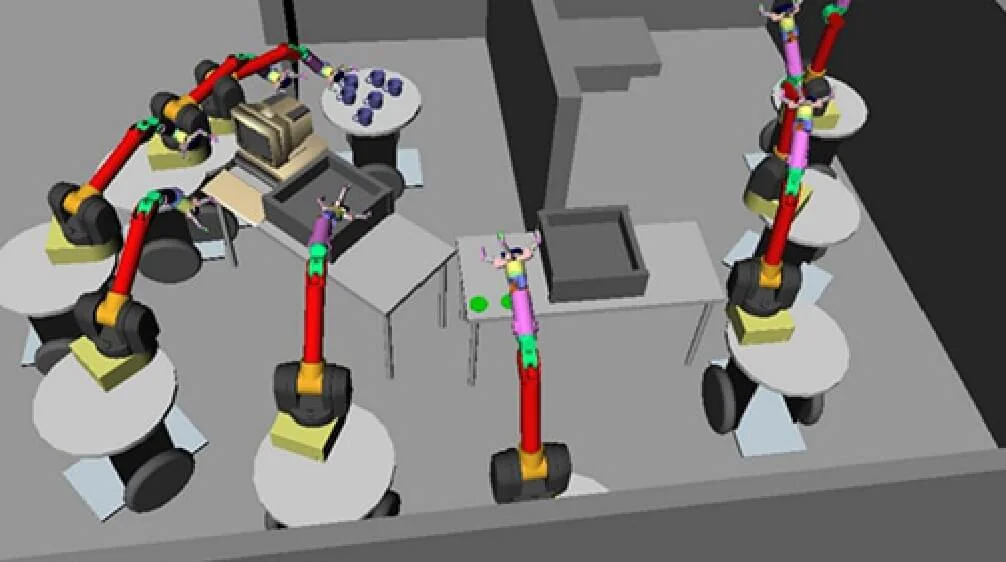
Real-time continuous collision detection in high-dimensional configuration space (C-space) ensuring smooth, jerk-minimized trajectories
MujinMI constructs a continuous **real-time digital twin** of the operating environment. Rather than following static paths, the motion planner dynamically computes optimal trajectories in high-dimensional configuration space ($C$-space). It optimizes:
- **Jerk and Acceleration Constraints:** Minimizing mechanical vibration and motor wear to prolong equipment lifespan.
- **Inertial Load Balancing:** Adjusting acceleration profiles dynamically based on real-time payload mass and gripper grasp offsets.
- **Dynamic Obstacle Avoidance:** Rerouting in mid-motion if human operators, mobile AGVs, or adjacent robots enter shared envelopes.
---
#### 3. Situational 3D Perception & Scene Assessment
Vision in logistics cannot simply draw 2D bounding boxes. Warehouses present complex visual challenges: overlapping parcels, inter-reflections from plastic wrapping, and fluctuating lighting from open dock doors.
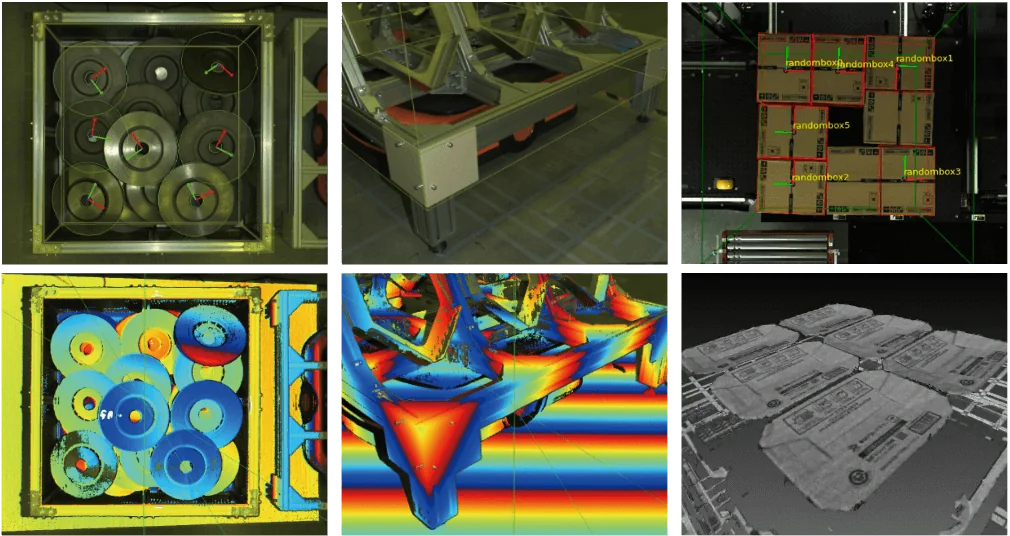
From dense 3D point cloud capture to contextual scene understanding: segmenting zero-gap cases and computing pick points
Mujin's 3D vision algorithms extract dense point clouds, perform precise surface normal estimation, and execute situational reasoning:
- Accurately detecting cardboard seams between flush, zero-gap boxes.
- Recognizing surface tilt, sag, and deformable contours on heavy bags.
- Filtering specular highlights and reflections from metallic parts and stretch-wrapped pallets.
---
### Unrivaled Industrial Reliability: 1 in 40,000 Error Tolerance
In logistics operations running 24/7, even a 1% error rate means hundreds of line stoppages per shift. MujinMI sets the industry standard for production robustness:
1 in 40,000
Field-Proven Reliability
Production benchmarks in high-throughput fulfillment centers demonstrate failure rates as low as one error in 20,000 to 40,000 consecutive pick-and-place operations.
Why Production Leaders Choose MujinMI
Hardware Agnostic: Controls robots from FANUC, Yaskawa, Kawasaki, Mitsubishi Electric, KUKA, and ABB under a unified interface.
Zero Robot Teaching: Completely eliminates the need for manual teaching pendant programming.
Predictable ROI: Digital twin simulations validate throughput and cycle times before capital commitment.
---
### Explore Mujin Technology
**[Read: Universal MujinController](/about-mujin/technology)**
Learn how MujinController coordinates arms, vision systems, and AGVs under unified digital twin intelligence.
**[Software Engineering Careers](https://mujin-corp.com/careers/)**
Join the algorithmic minds building the world's most advanced autonomous robot motion planning engines.