---
title: "From MIT to Mujin: What Top Robotics Minds Experience on the Frontlines"
description: "MIT mechanical engineer Kenji and robotics master's student Zachary reflect on their 3-month internships at Mujin—from deploying real-world damper mechanisms on 20kg grippers to optimizing automated pose generation on multi-ton industrial manipulators."
type: blog
publishDate: "2023-12-20"
tags: ["Internship", "Engineering", "Robotics", "Culture", "Global"]
---
Welcome to another edition of our "Mujinians Voice" series!
Today, we feature two engineering students from the **Massachusetts Institute of Technology (MIT)**—**Kenji** and **Zachary**—who joined Mujin's Tokyo headquarters for an intensive 3-month summer robotics internship.
How does cutting-edge engineering on active industrial floors differ from university laboratories and personal hobby projects? They reflect on their hands-on journey designing hardware and algorithms for production industrial manipulators.
**From MIT to the Gemba**
Global Minds at the Frontier
Stepping out of sanitized university simulations to deploy physical robots in mission-critical logistics facilities.
**Physical Manipulators**
Direct Hardware Ownership
From engineering 20kg gripper damper assemblies to writing automated 6-DoF pose generation algorithms on expensive arms.
**Zero Margin for Error**
Designing for Reliability
Unlike hobby builds where failure is harmless, automated factory cells running 24/7 demand uncompromising, repeatable reliability.
---
## Part 1: Kenji (MIT Mechanical Engineering) — Designing Damper Assemblies for 20kg Grippers
*-- Starting early in your undergraduate studies, what motivated you to pursue an internship at Mujin?*
> 💬 **Kenji:**
> I wanted to gain authentic hands-on experience with production robotics in real-world contexts.
> Mechanical engineering applied on a factory floor behaves very differently from controlled university laboratories. By bridging academic theory with Mujin's practical engineering, I knew I could accelerate my growth and make a tangible real-world contribution.
*-- What specific engineering project did you own during your internship?*
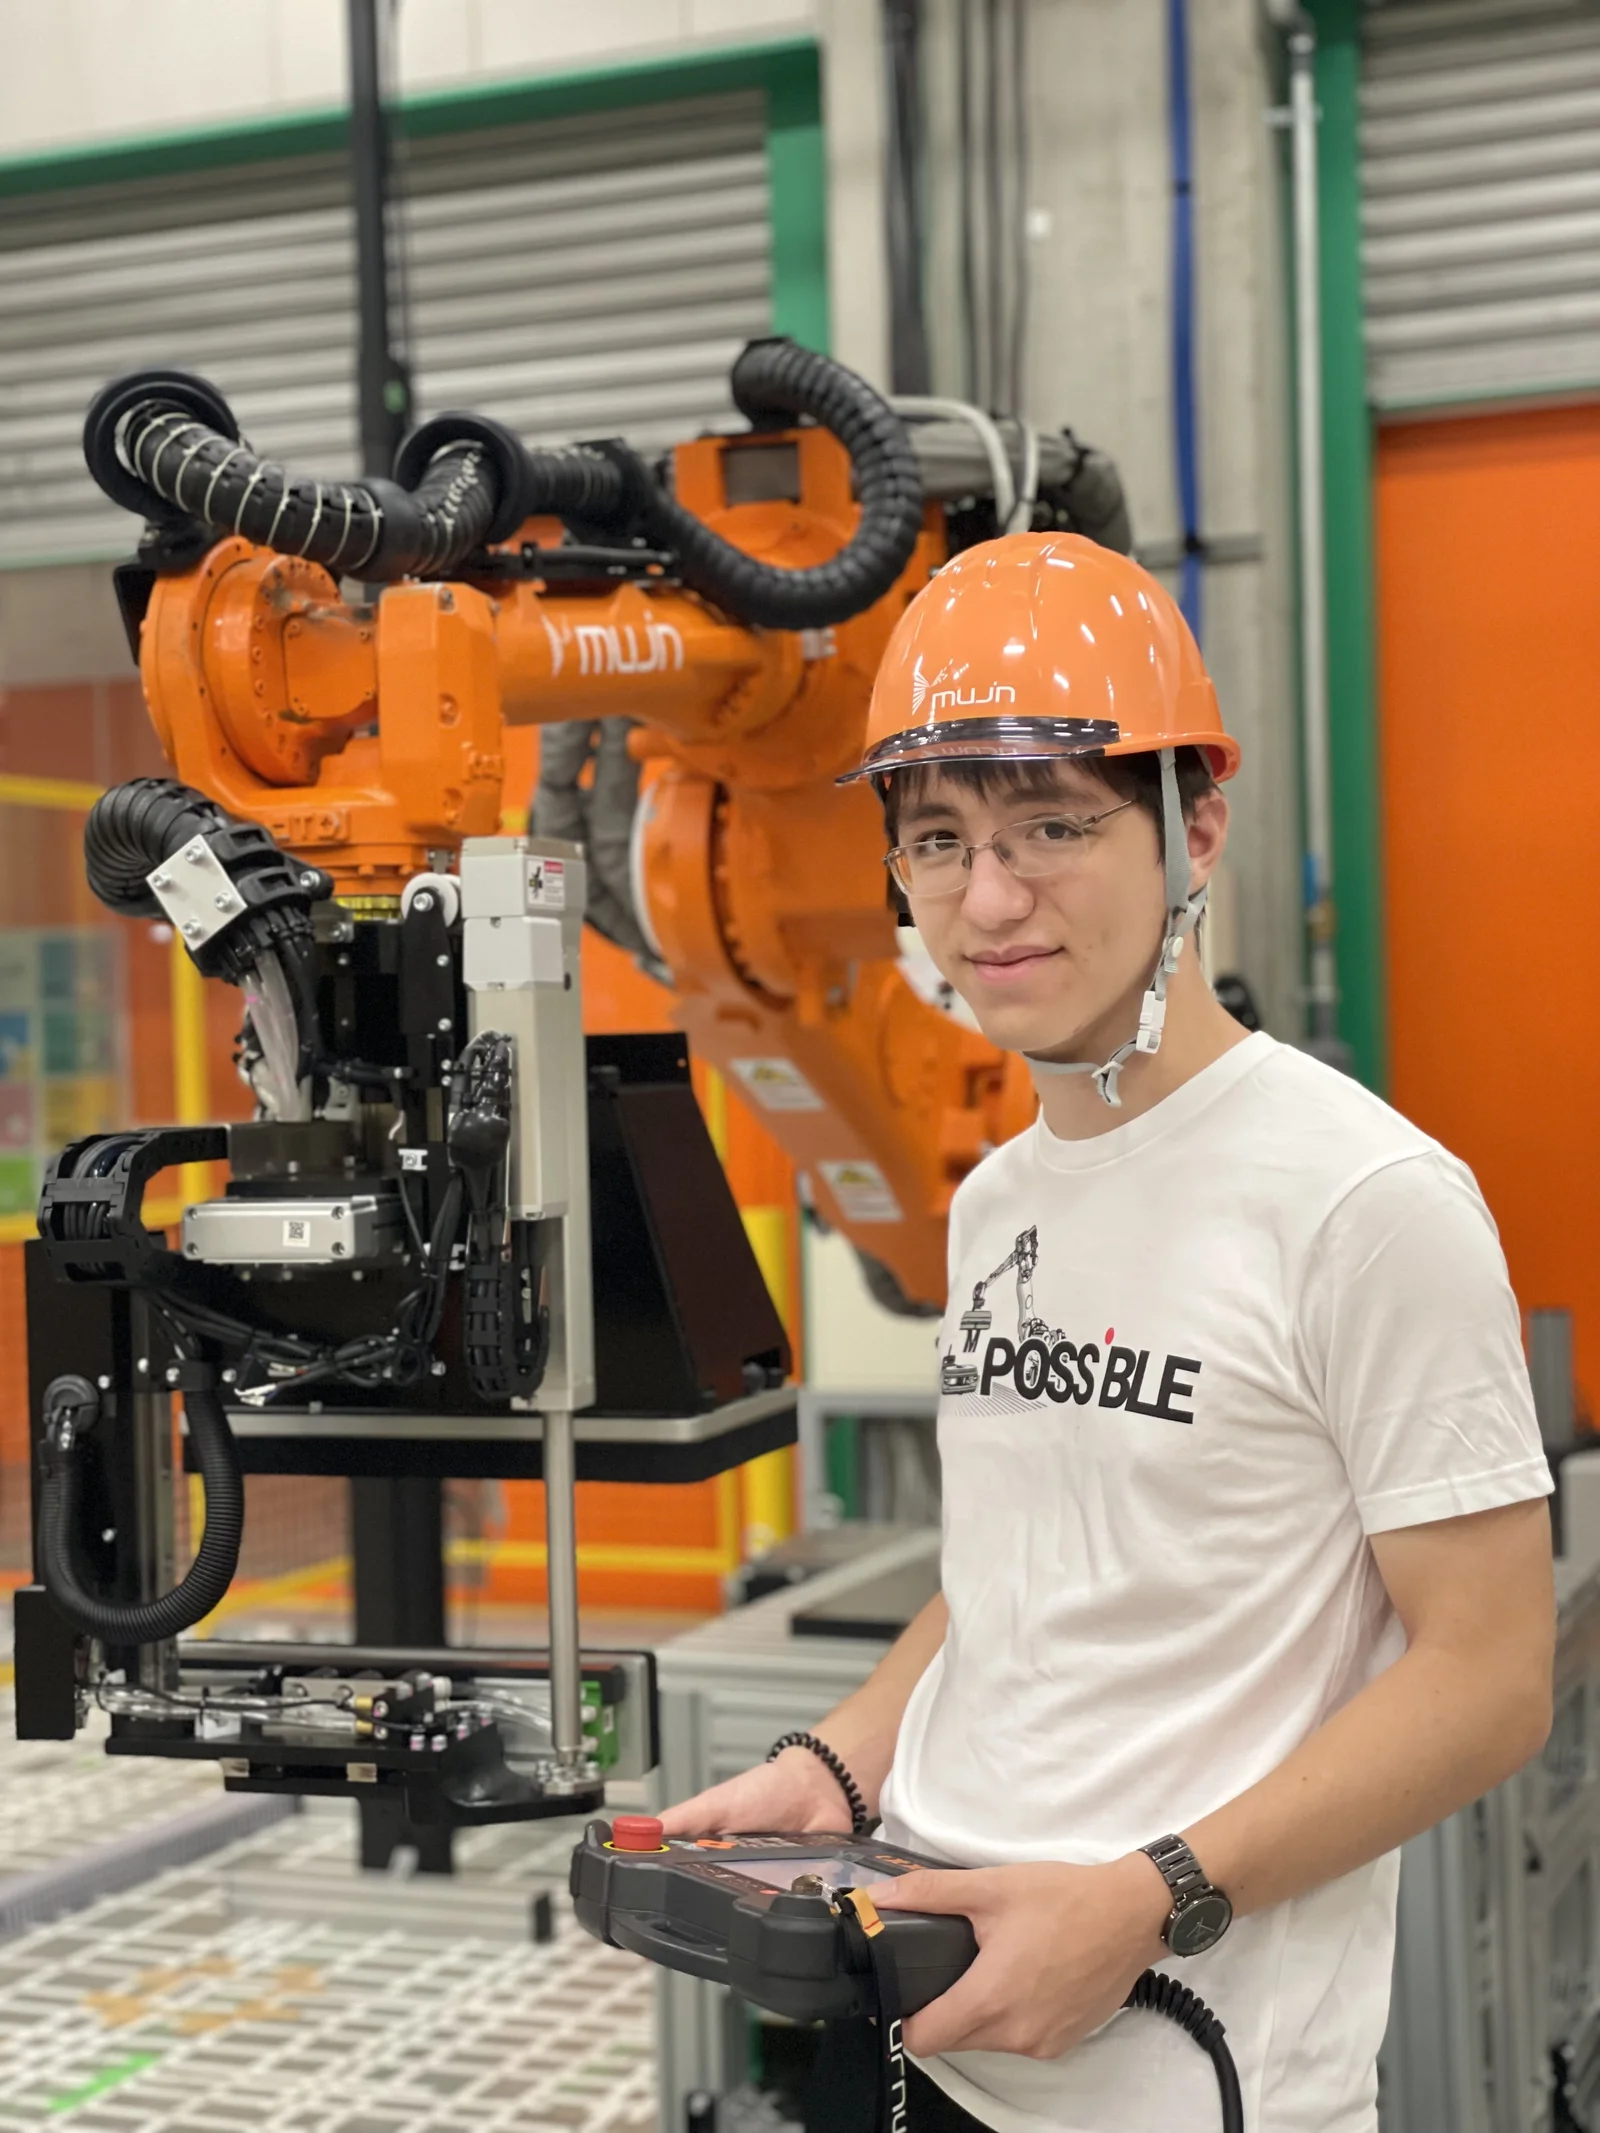
3D CAD design of the collision-absorbing damper assemblyAssembling and validating hardware with the manufacturing team
> 💬 **Kenji:**
> I engineered a custom damper assembly for an industrial gripper. In warehouse automation, unexpected operator errors or packaging misalignments can occasionally cause a gripper to bump vertically into cartons, bending and damaging the vacuum suction side pads.
>
> To resolve this, I developed a spring-loaded damper assembly that allows the end-effector to slide upward smoothly upon contact, absorbing the impact energy before damage can occur. An embedded sensor triggers an immediate safety stop.
> The entire gripper weighs approximately 20 kilograms. We tested multiple spring constants to ensure that under 2G arm acceleration, the assembly remains completely rigid without bouncing, yet moves cleanly when an impact is registered.
:::note[Kenji's Key Takeaway: The Mindset of "Designing for Reliability"]
In personal maker projects, when a part breaks, you just fix it and move on. But in a high-throughput industrial plant processing tens of thousands of packages daily, **a single mechanical failure is unacceptable**. Learning how to architect hardware for flawless, repeated duty cycles under intense dynamic forces was the most valuable lesson of my engineering education.
:::
---
## Part 2: Zachary (MIT Robotics Master's) — Optimizing Real-Time Automated Pose Generation
*-- What inspired you to specialize in robotics, and why choose Mujin?*
> 💬 **Zachary:**
> Growing up, I was obsessed with giant robot anime, dreaming of making robots real. Japan is globally renowned for robotics innovation, so spending a summer working here was a dream come true.
>
> What stood out immediately was Mujin's exceptional organizational support. From visa sponsorship to securing Tokyo accommodations and organizing cultural integration events, the Talent Acquisition team ensured that I never had to worry about logistics.
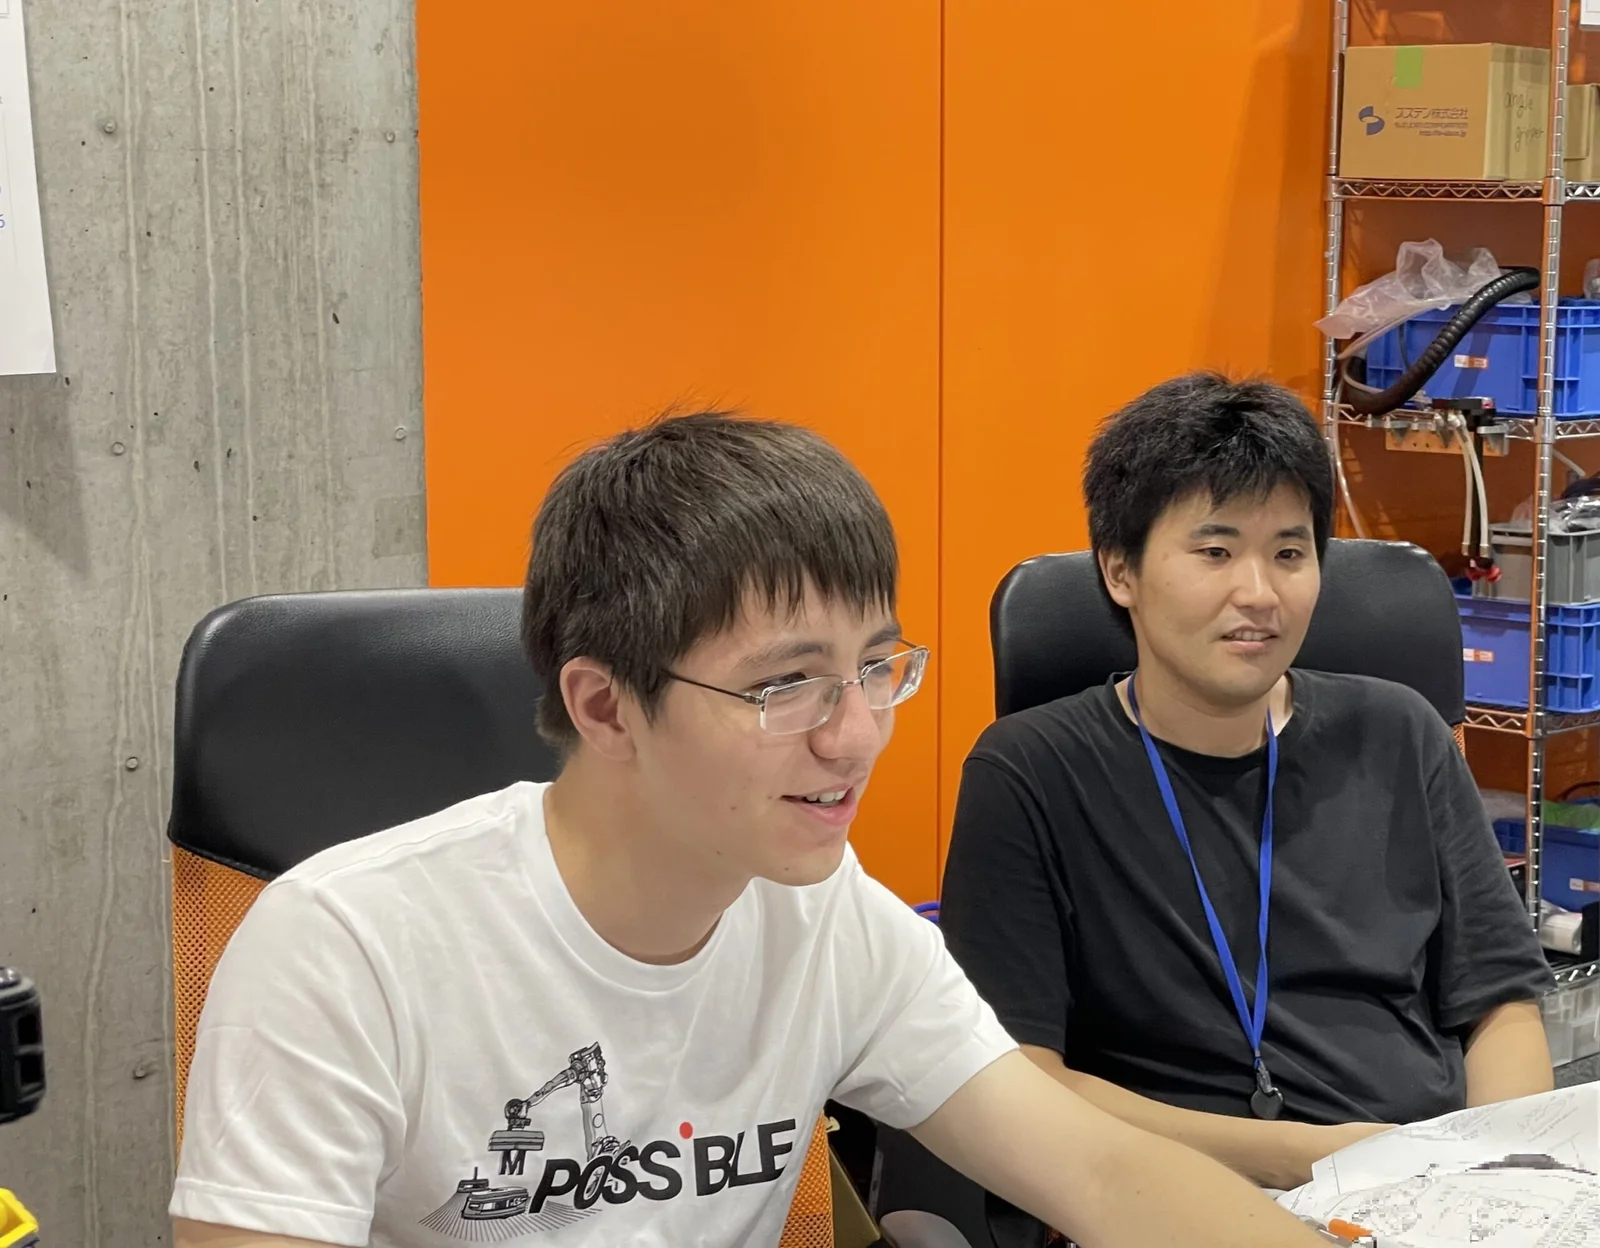
Iterating on algorithm architecture with mentor EisokuValidating pose generation directly on multi-ton industrial manipulators
*-- How was your experience working with your mentor and testing on real robots?*
> 💬 **Zachary:**
> My mentor, Eisoku, was fantastic—always patient, supportive, and dedicated to teaching me disciplined engineering problem-solving. Beyond the robotics team, I collaborated closely with frontend engineers, learning modern web development frameworks for robot interfaces.
>
> What inspired me most was living Mujin's core value: **"Pursue the highest quality."**
> When I first developed an algorithm for automatic pose generation, it worked correctly, but its runtime was too slow for high-speed logistics. Guided by Eisoku, we analyzed profiling data, eradicated computational bottlenecks, and achieved a dramatic speedup. Mujin entrusted me with expensive industrial manipulators from day one. That trust pushed me to elevate my standards as a software engineer.
---
## 3. Advice for Aspiring Student Roboticists
*-- What advice do you have for students seeking internships at Mujin?*
> 💬 **Kenji:**
> Don't obsess solely over textbook grades, GPA, or competitive programming scores. What truly stands out is **dedicating serious effort to hands-on personal projects that genuinely ignite your curiosity**. Demonstrating that you can design, build, and debug real systems is what matters most at Mujin.
>
> 💬 **Zachary:**
> Because English is Mujin's primary engineering language, you don't need Japanese proficiency to contribute from day one. Most importantly, Mujin treats interns as full-fledged engineers. You don't get assigned trivial toy problems; you work on systems that end up in production facilities. If you want to build autonomous systems that shape the physical world, Mujin is unbeatable!
---
:::tip[Mujin Robotics Technology Internship Program]
Mujin regularly accepts undergraduate, master's, and PhD interns across Software Engineering, Computer Vision, Motion Planning, and Mechanical Integration.
- Application details: [Mujin Global Internship Program](https://mujin.co.jp/en/internship-program/)
- Full-time career openings: [Mujin Careers Portal](https://jobs.lever.co/mujininc)
- Engineer stories: [Lead Robotics Engineer Denys on Early Mujin Days](/blog/mujinian-voice-robotics)
:::