---
title: "Ace Your Computer Vision Job Interview at Mujin"
description: "Practical tips on how to prepare for a Computer Vision Engineer interview at Mujin: domain fundamentals, 3D perception vs. 2D bounding boxes, technical interview stages, sample questions, and curated study resources."
type: blog
publishDate: "2021-06-28"
tags: ["Blog", "Mujin", "Careers", "Engineering"]
---

Whether you are a seasoned robotics engineer or an aspiring researcher preparing for technical interviews, understanding the exact expectations of a computer vision role in industrial automation is crucial.

At Mujin, our Computer Vision team develops the "eyes" of autonomous industrial robots—enabling machines to perceive, understand, and interact with complex 3D environments in real time. This guide breaks down what we look for during the technical interview process, the fundamental skills you will need, and sample questions to test your knowledge.

<figure className="my-8 text-center">
  <img
    src="/blog/2023/05/IMG_1021-768x1024.webp"
    alt="Mujin Engineer working on 3D Vision Systems"
    className="rounded-xl shadow-md w-full object-cover max-h-96 mx-auto"
  />
  <figcaption className="text-xs text-gray-500 dark:text-gray-400 mt-2">
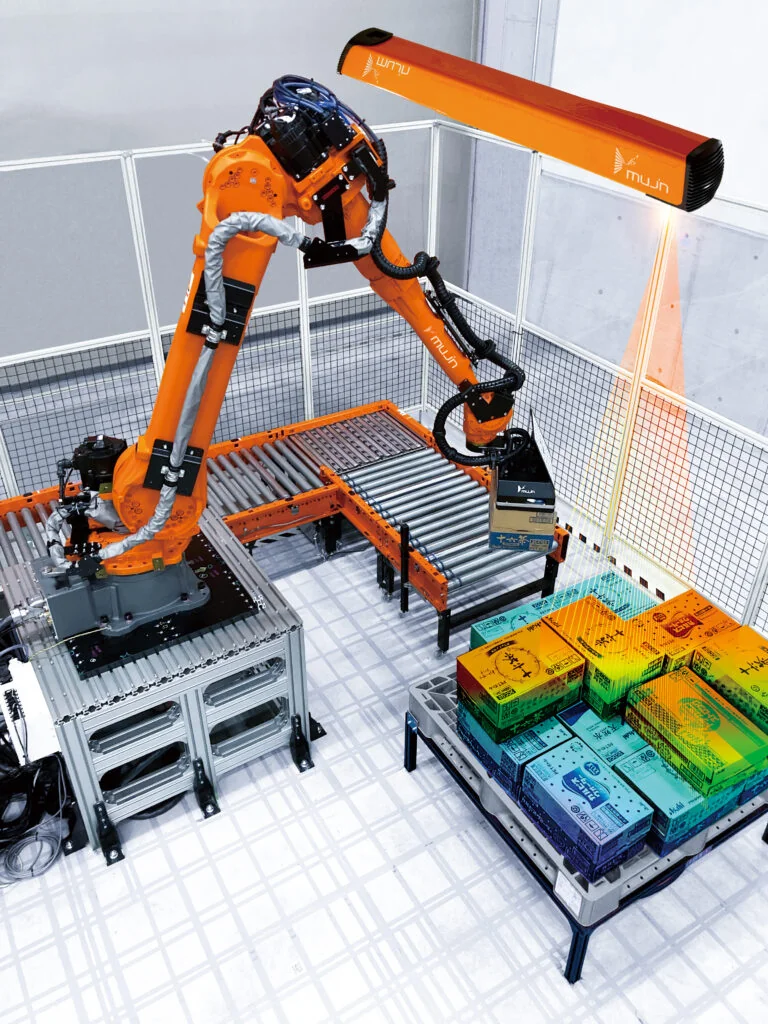
    Engineering at Mujin: Bridging cutting-edge 3D perception algorithms with factory-floor reliability
  </figcaption>
</figure>

:::note[Beyond 2D Image Processing: True 3D Spatial Intelligence]
In many software domains, "computer vision" refers primarily to 2D image processing, convolutional neural networks, or drawing 2D bounding boxes on photos. At Mujin, computer vision is fundamentally about **3D spatial intelligence**: reconstructing physical scenes with millimeter precision, estimating full 6-DoF poses, and enabling real-time robot arm manipulation.
:::

---

### Step 1: Understand the Domain & Specialize Your Preparation

The first and most critical step is to tailor your interview preparation to the specific system domain you are applying for. The mathematical formulations and sensor configurations differ drastically across applications:

**Autonomous Vehicles & Mobile Robots (AGVs)**

<strong>Gravity-Aligned Constraints</strong><br />
Cameras and LiDAR sensors are typically aligned with gravity, greatly simplifying obstacle avoidance and pedestrian detection by eliminating arbitrary pitch and roll rotations.

**Drones & Satellite Imagery**

<strong>Top-Down Bird's Eye Geometry</strong><br />
High-altitude viewpoints reduce 3D scenes to roughly planar 2D representations, prioritizing rapid localization, tile mapping, and low-resolution classification over depth sensing.

**Augmented Reality (AR)**

<strong>Real-Time SLAM & Device Tracking</strong><br />
Focuses on simultaneous localization and mapping (SLAM), sparse feature tracking, and visual-inertial odometry to anchor virtual animations onto static surfaces.

**Industrial Robotic Manipulation (Mujin)**

<strong>Full 6-DoF Perception Under Chaos</strong><br />
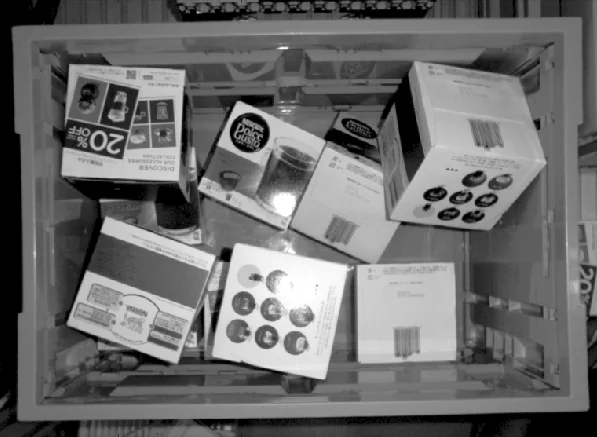
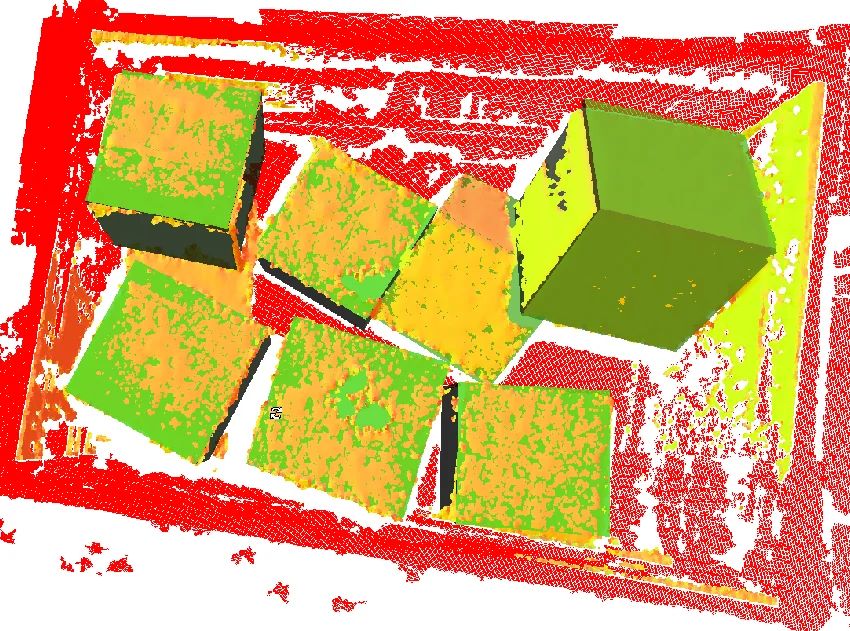
Workpieces arrive with unconstrained orientations (no gravity prior). Algorithms must tackle extreme clutter, mutual occlusions, and severe specular reflections on metal or plastic.

<div className="grid grid-cols-1 md:grid-cols-2 gap-6 my-8">
  <figure className="m-0 text-center">
    <img
      src="/blog/2021/06/Image-Pasted-at-2021-6-25-18-41.a.webp"
      alt="Complex 3D Point Cloud and Grasp Calculation"
      className="rounded-xl shadow-md w-full object-cover max-h-64"
    />
    <figcaption className="text-xs text-gray-500 dark:text-gray-400 mt-2">
      Multi-angle point cloud capture: resolving dense occlusions and arbitrary orientations
    </figcaption>
  </figure>
  <figure className="m-0 text-center">
    <img
      src="/blog/2021/06/Image-Pasted-at-2021-6-25-18-41.webp"
      alt="Segmenting specular and irregular workpieces"
      className="rounded-xl shadow-md w-full object-cover max-h-64"
    />
    <figcaption className="text-xs text-gray-500 dark:text-gray-400 mt-2">
      Handling inter-reflection, specular highlights, and deformable packaging on the fly
    </figcaption>
  </figure>
</div>

---

### Step 2: What to Expect in Mujin's Technical Interview

Our technical evaluation is designed to assess your practical, hands-on engineering capabilities rather than rote memorization.

<figure className="my-8 text-center">
  <img
    src="/blog/2023/05/表紙_03-1024x660.webp"
    alt="Mujin Engineering Team"
    className="rounded-xl shadow-md w-full object-cover max-h-72 mx-auto"
  />
  <figcaption className="text-xs text-gray-500 dark:text-gray-400 mt-2">
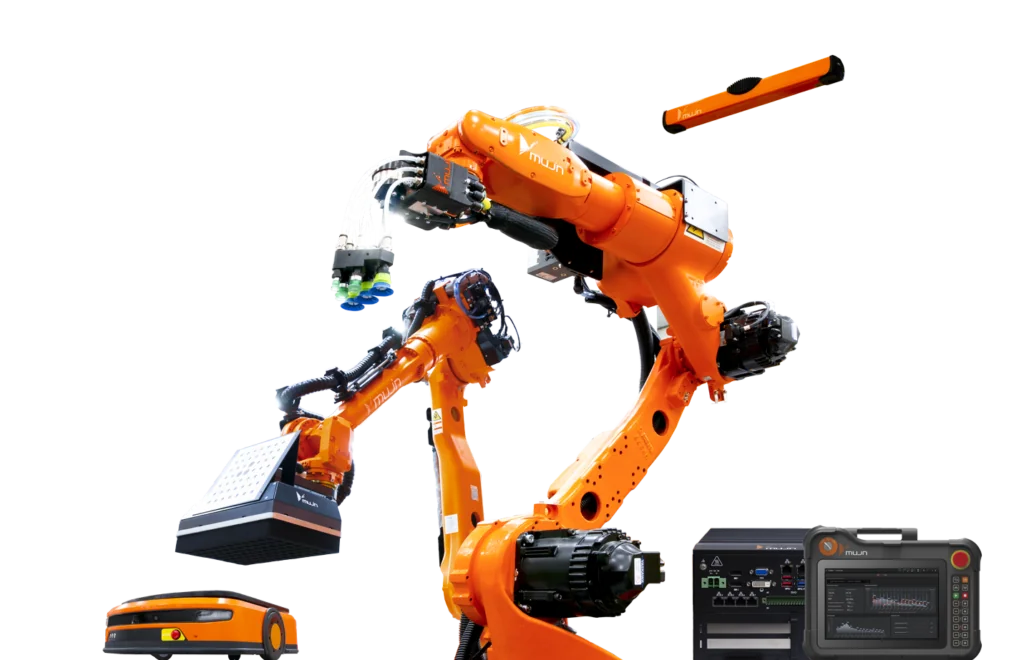
    Mujin engineering interviews evaluate how you apply core computer science to production robotics
  </figcaption>
</figure>

**1. C++ & Python**

Demonstrate mastery in C++ (memory safety, performance, concurrency) alongside Python for rapid prototyping, data pipelines, and algorithm experimentation.

**2. Applied Math & Geometry**

Deep comfort with linear algebra, SE(3) transformation matrices, quaternions, epipolar geometry, and numerical optimization libraries.

**3. Real-World Robustness**

Understanding physical sensor characteristics: shutter timing, motion blur, active projection, calibration drift, and edge cases in dirty environments.

---

### Step 3: Deep-Dive Technical Questions to Practice

Here are sample questions reflecting the concepts discussed in our interviews:

<div className="space-y-6 my-8">
  <div className="border border-gray-200 dark:border-gray-800 rounded-xl p-6 bg-gray-50/60 dark:bg-gray-900/40">
    <h4 className="text-base font-bold text-gray-900 dark:text-gray-100 m-0 pb-2 border-b border-gray-200 dark:border-gray-800">
      Question 1: How do you project a 3D point onto an image plane?
    </h4>
    <p className="text-sm text-gray-700 dark:text-gray-300 mt-3 mb-2">
      <strong>Key Insight:</strong> The first clarifying question you should ask is: <em>"In what coordinate frame is the 3D point currently defined?"</em>
    </p>
    <ul className="text-xs text-gray-600 dark:text-gray-400 space-y-1 list-disc pl-5">
      <li>If in world/robot coordinates, you must first apply a rigid body extrinsic transform $[R \mid t]$ to express the point in the camera frame.</li>
      <li>Next, multiply by the intrinsic camera matrix $K$ (focal lengths $f_x, f_y$ and principal point $c_x, c_y$).</li>
      <li>Finally, account for lens distortion (radial coefficients $k_1, k_2, k_3$ and tangential coefficients $p_1, p_2$) before projecting to pixel space $(u, v)$.</li>
    </ul>
  </div>

  <div className="border border-gray-200 dark:border-gray-800 rounded-xl p-6 bg-gray-50/60 dark:bg-gray-900/40">
    <h4 className="text-base font-bold text-gray-900 dark:text-gray-100 m-0 pb-2 border-b border-gray-200 dark:border-gray-800">
      Question 2: How do you extract metric 3D measurements using multiple 2D camera views?
    </h4>
    <p className="text-sm text-gray-700 dark:text-gray-300 mt-3 mb-2">
      <strong>Key Insight:</strong> This requires demonstrating a firm grasp of stereo vision and epipolar geometry:
    </p>
    <ul className="text-xs text-gray-600 dark:text-gray-400 space-y-1 list-disc pl-5">
      <li>Understanding the essential matrix $E = [t]_\times R$ (normalized coordinates) versus the fundamental matrix $F = K'^{-T} E K^{-1}$ (pixel space).</li>
      <li>Epipolar line constraints ($x'^T F x = 0$) to narrow corresponding feature searches from 2D planes to 1D lines.</li>
      <li>Triangulation and baseline trade-offs: wider baselines yield higher depth precision but increase occlusions and matching ambiguity.</li>
    </ul>
  </div>

  <div className="border border-gray-200 dark:border-gray-800 rounded-xl p-6 bg-gray-50/60 dark:bg-gray-900/40">
    <h4 className="text-base font-bold text-gray-900 dark:text-gray-100 m-0 pb-2 border-b border-gray-200 dark:border-gray-800">
      Question 3: How do you formulate 6-DoF object pose estimation from noisy point clouds?
    </h4>
    <p className="text-sm text-gray-700 dark:text-gray-300 mt-3 mb-2">
      <strong>Key Insight:</strong> In production picking, objects are rarely simple bounding boxes:
    </p>
    <ul className="text-xs text-gray-600 dark:text-gray-400 space-y-1 list-disc pl-5">
      <li>Representing 3D orientation without gimbal lock: rotation matrices in $SO(3)$ or unit quaternions.</li>
      <li>Global coarse alignment using geometric feature descriptors (e.g., FPFH) followed by local fine alignment via Iterative Closest Point (ICP) or Point-to-Plane variants.</li>
      <li>RANSAC filtering to reject outliers and handle occluded or partially overlapping workpieces.</li>
    </ul>
  </div>
</div>

---

### Step 4: Recommended Study Resources

To refresh your mathematical foundations and stay current with state-of-the-art vision literature, we highly recommend the following freely available academic resources:

**[Convex Optimization (Boyd & Vandenberghe)](https://web.stanford.edu/~boyd/cvxbook/)**

Stanford's definitive textbook on convex optimization, least squares, and non-linear numerical solvers.

**[CMU Computer Vision (CS 15-385)](http://www.cs.cmu.edu/afs/cs/academic/class/15385-s12/www/)**

Prof. Srinivasa Narasimhan's course covering physics of image formation, camera geometry, and multi-view stereo.

**[3D Computer Vision (University of Utah)](http://www.sci.utah.edu/~gerig/CS6320-S2015/CS6320_3D_Computer_Vision.html)**

Prof. Guido Gerig's course focused specifically on range sensing, surface reconstruction, and 3D registration.

**[3D Sensor Lecture Series (INRIA)](http://perception.inrialpes.fr/people/Horaud/Courses/3DS_2013.html)**

Radu Horaud's masterclass on active 3D sensors, time-of-flight cameras, and point cloud processing.

---

### Join the Computer Vision Team at Mujin

Are you excited to solve real-world perception challenges and deploy autonomous robotics across global factories and warehouses? We are actively hiring Computer Vision Engineers, Robotics System Engineers, and Software Architects across Tokyo, Atlanta, and Eindhoven.

**[Open Computer Vision Positions](https://jobs.lever.co/mujininc?department=1%20-%20Software%20Development&team=Computer%20Vision%20Team)**

Review active job openings and submit your application directly to the CV engineering group.

**[Explore Mujin Engineering Careers](https://mujin-corp.com/careers/)**

Learn more about our relocation support, engineering culture, and the MujinController platform.